This article was drafted with the help of AI tools and has been reviewed, refined, and edited by the author before publication.
Technology · Artificial Intelligence · Autonomous Vehicles
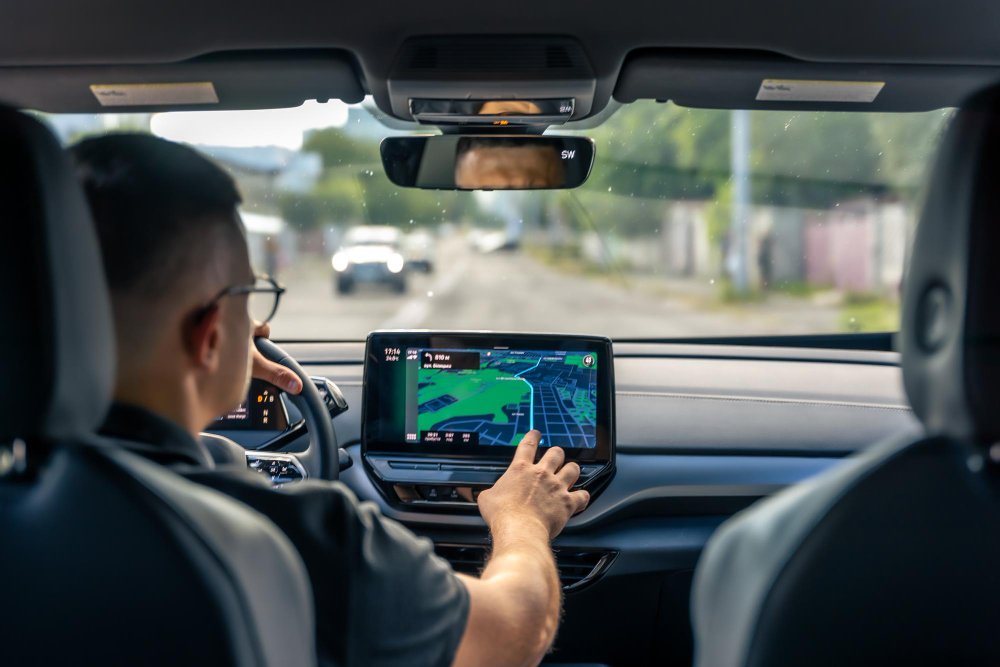
Imagine sitting inside a car moving through a busy city intersection. There is no one holding the steering wheel. A cyclist suddenly enters the road, a pedestrian approaches the crossing, and another vehicle changes lanes without warning. Yet the car slows down, calculates the available space, and adjusts its direction.
How does it know what is happening around it?
Self-driving cars do not see the world in the same way humans do. They do not rely on a pair of eyes or instinctive reactions. Instead, they use a combination of cameras, radar, LiDAR, artificial intelligence, computer vision, and advanced computing systems to interpret their surroundings.
What makes this technology particularly interesting is that a self-driving vehicle must do more than recognize objects. It must estimate distances, predict movement, identify potential hazards, interpret road markings, and make decisions within fractions of a second.
In other words, autonomous vehicles are not simply looking at the road. They are continuously building and updating a digital representation of everything happening around them.
To understand how this works, it helps to examine the technology behind the vehicle’s perception system, the challenges engineers face, and the practical consequences of giving machines the responsibility of navigating real roads.
A Self-Driving Car Does Not Have Just One Pair of Eyes
A common misconception is that autonomous vehicles rely on a single advanced camera to recognize everything around them. In reality, many self-driving systems combine several types of sensors because each technology has different strengths and weaknesses.
A camera can identify a traffic sign, but estimating its exact distance can be difficult. Radar can measure the distance and relative speed of nearby vehicles, but it generally provides less visual detail. LiDAR can create highly accurate three-dimensional measurements, although its performance and usefulness depend on environmental conditions and system design.
Combining these technologies gives the vehicle a more complete picture of its environment.
This approach is known as sensor fusion.
Rather than trusting one source of information, the vehicle’s computer compares observations from multiple sensors to produce a more reliable estimate of what is happening around it.
1. Cameras: How Cars Recognize the World Visually
Cameras are among the most recognizable components of autonomous driving technology. They capture images of the environment and provide visual information that AI systems can analyze.
Modern autonomous vehicles may use several cameras positioned around the vehicle, including:
- Front-facing cameras for identifying vehicles, road signs, and traffic signals.
- Side-facing cameras for monitoring adjacent lanes and approaching traffic.
- Rear-facing cameras for observing vehicles behind the car.
- Wide-angle cameras for capturing nearby objects and areas that might otherwise remain outside the field of view.
The important part is not simply capturing an image. It is interpreting what the image contains.
Computer Vision Makes Camera Images Useful
Computer vision is a branch of artificial intelligence that allows machines to analyze and interpret visual information.
When a self-driving car receives camera footage, its perception software can identify different objects and classify them.
For example, it may recognize:
- A pedestrian waiting near a crossing.
- A motorcycle approaching from the left.
- A red traffic signal.
- A road marking indicating a turning lane.
- A vehicle braking ahead.
- A temporary construction barrier.
Deep learning models are commonly used to recognize patterns within these images. They are trained using large datasets containing examples of roads, vehicles, pedestrians, signs, and other objects.
However, recognizing an object is only the beginning.
The system also needs to estimate where that object is, how it is moving, and whether its movement creates a potential risk.
A camera may identify a pedestrian standing beside the road. The vehicle must then determine whether that person is likely to cross its path.
That is where perception connects with prediction.
2. LiDAR: Creating a Three-Dimensional Picture of the Road
LiDAR stands for Light Detection and Ranging. It is a sensing technology that uses laser pulses to measure distances between the sensor and surrounding objects.
A LiDAR system sends out laser light and measures how long it takes for reflected light to return.
Because light travels at a known speed, the system can calculate the distance to an object.
By collecting thousands or millions of measurements, the vehicle can create a three-dimensional representation of its surroundings.
This representation is often called a point cloud.
What Does a Point Cloud Actually Show?
Think of a digital image made entirely of individual points. Each point represents a measured location in physical space.
Together, these points can outline:
- The shape of another vehicle.
- The edges of buildings.
- Roadside structures.
- Trees and other obstacles.
- Pedestrians and cyclists.
- The boundaries of available driving space.
Unlike an ordinary photograph, a point cloud provides direct spatial measurements.
This makes LiDAR particularly useful when a vehicle needs to estimate the position and shape of nearby objects.
However, LiDAR is not a perfect solution. Heavy rain, fog, snow, dirt on the sensor, and other environmental conditions can affect measurements. The hardware can also increase vehicle cost and system complexity.
Some autonomous driving platforms use LiDAR extensively, while others rely on camera-based perception supported by different sensing technologies.
The choice depends on the manufacturer’s engineering approach and the operational environment.
3. Radar: Measuring Distance and Movement
Radar, short for Radio Detection and Ranging, uses radio waves to detect objects and estimate their distance and relative velocity.
It plays an important role in monitoring moving traffic.
Imagine a vehicle traveling at highway speed. Another car ahead suddenly begins slowing down.
A camera may identify the vehicle and its brake lights. Radar can independently measure changes in the distance between the two vehicles and estimate how quickly that distance is closing.
This information helps the autonomous driving system evaluate whether it needs to reduce speed.
Radar is especially valuable because it generally performs well in conditions where cameras may struggle, including darkness, rain, and certain visibility limitations.
Its strengths include:
- Measuring the distance to nearby objects.
- Estimating relative speed.
- Monitoring vehicles in adjacent lanes.
- Supporting adaptive cruise control.
- Helping detect potential collisions.
Radar does have limitations. Compared with cameras and high-resolution LiDAR systems, it generally provides less detailed information about an object’s visual appearance and precise shape.
That is why combining sensor technologies is so important.
4. Sensor Fusion: Combining Different Sources of Information
Imagine asking three people to describe the same busy intersection.
One person focuses on vehicle movement. Another watches pedestrians. The third pays attention to road signs and traffic signals.
Each person notices something different.
Sensor fusion follows a similar principle, except the information comes from electronic sensors rather than human observers.
The vehicle’s computing system combines camera images, radar measurements, LiDAR point clouds, and sometimes other sensor data.
It then attempts to create a consistent representation of the surrounding environment.
For example, suppose a camera identifies a car in the next lane. Radar measures its speed and distance, while LiDAR provides additional information about its position and physical dimensions.
The system can associate these observations with the same object.
This process helps reduce uncertainty and improves the vehicle’s ability to respond to changing road conditions.
Sensor fusion is not simply about collecting more data. It is about determining which measurements are reliable, how they relate to one another, and what conclusions can reasonably be drawn from them.
5. Ultrasonic Sensors: Detecting Objects at Close Range
Not every driving situation requires long-distance sensing.
When a vehicle parks, moves through a narrow space, or approaches an obstacle at low speed, it needs accurate information about nearby objects.
This is where ultrasonic sensors become useful.
These sensors transmit high-frequency sound waves and measure how long the reflected waves take to return. The system uses that information to estimate the distance between the vehicle and an obstacle.
You may already be familiar with this technology through parking assistance systems.
In autonomous vehicles, ultrasonic sensors can help detect:
- Nearby walls and barriers.
- Vehicles parked alongside the car.
- Objects close to the front or rear bumper.
- Obstacles during low-speed manoeuvres.
- Available space when entering or leaving a parking position.
Ultrasonic sensors generally have a shorter operating range than radar or LiDAR. They are therefore supporting components rather than replacements for the vehicle’s main perception equipment.
6. GPS and IMU: Knowing Where the Car Is
Seeing surrounding objects is only half the challenge. A self-driving car also needs to know its own position.
This requires localization.
GPS and other Global Navigation Satellite System (GNSS) technologies help estimate the vehicle’s geographic location. However, satellite positioning alone may not provide sufficient accuracy for complex autonomous driving situations.
For example, a vehicle traveling between tall buildings may experience satellite signal interference or reflections.
An Inertial Measurement Unit (IMU) provides another source of information. It measures acceleration and rotational movement using accelerometers and gyroscopes.
By combining satellite positioning, IMU measurements, wheel movement data, and information from surrounding landmarks, the vehicle can estimate its position and movement more reliably.
This combination is particularly important when navigating:
- Urban streets surrounded by buildings.
- Underground parking facilities.
- Complex road intersections.
- Highways with multiple lanes.
- Areas where satellite signals are temporarily unavailable.
Localization allows the vehicle to connect what its sensors observe with where it is positioned in the wider environment.
7. Artificial Intelligence Turns Sensor Data Into Meaning
Here is where the technology becomes considerably more sophisticated.
A camera produces pixels. LiDAR produces point clouds. Radar produces measurements. GPS and IMU systems provide positioning and movement information.
None of these outputs independently tells a vehicle exactly what action it should take.
Artificial intelligence processes these inputs and helps convert them into useful information.
Several computer vision and machine learning techniques contribute to this process.
Object Detection
Object detection identifies relevant objects within an image or sensor representation.
A vehicle might identify a bus, pedestrian, motorcycle, bicycle, traffic sign, or road barrier.
The system can also estimate the location of each detected object.
Semantic Segmentation
Object detection identifies individual objects. Semantic segmentation goes further by assigning categories to different areas of an image.
For example, the system can distinguish:
- Road surfaces.
- Sidewalks.
- Buildings.
- Vegetation.
- Lane markings.
- Pedestrian crossings.
- Other vehicles.
This helps the vehicle determine which areas are potentially safe to drive through.
Object Tracking
Recognizing an object in one frame is not enough.
A self-driving vehicle receives a continuous stream of sensor information. It needs to identify whether an object appearing in the next frame is the same object it previously detected.
Object tracking helps maintain this continuity.
For example, if a motorcycle is approaching from the right, the vehicle needs to monitor its changing position and speed rather than treating every camera frame as a completely new situation.
Confidence Estimation
AI systems can also assign confidence scores to their predictions.
Suppose the vehicle’s camera detects something that might be a pedestrian, but part of the object is hidden behind a parked vehicle.
The system may have less confidence in its classification.
A reliable autonomous driving architecture must account for this uncertainty rather than treating every prediction as unquestionably correct.
This distinction is particularly important in safety-critical environments.
8. How a Self-Driving Car Predicts What Happens Next
Recognizing the present is useful. Predicting the immediate future is essential.
Consider a pedestrian standing near a zebra crossing.
The vehicle may identify the person, estimate their location, and track their movement. However, it must also evaluate whether they are likely to step onto the road.
This is known as motion prediction or trajectory prediction.
AI models analyze information such as:
- The object’s current position.
- Its previous movement.
- Its estimated speed.
- The direction it is facing or traveling.
- The surrounding road layout.
- The movement of nearby road users.
- Traffic signals and other relevant conditions.
The system then estimates possible future trajectories.
Importantly, it cannot know exactly what another road user will do. A pedestrian may suddenly change direction, or a cyclist may move around an obstacle.
For that reason, autonomous vehicles need to consider multiple possible outcomes rather than relying on a single prediction.
Imagine a car approaching an intersection where a cyclist is moving alongside it.
The system may calculate several possibilities:
- The cyclist continues straight.
- The cyclist slows down.
- The cyclist turns across the vehicle’s path.
The vehicle can then evaluate the risks associated with each possibility and choose an appropriately cautious response.
9. From Seeing to Driving: How the Vehicle Makes Decisions
Perception and prediction provide information, but the vehicle still needs to decide what to do.
Autonomous driving systems generally involve three closely connected stages:
1. Perception
Identifies vehicles, pedestrians, road boundaries, traffic signals, and other relevant objects.
2. Prediction
Estimates how surrounding objects may move over the next few seconds.
3. Planning
Selects a suitable driving path, speed, and manoeuvre based on the available information.
Once a driving decision has been selected, the vehicle’s control system translates it into physical commands.
These may include:
- Adjusting the steering angle.
- Increasing or reducing acceleration.
- Applying the brakes.
- Maintaining a safe following distance.
- Changing lanes when appropriate.
This entire process operates continuously. The vehicle cannot simply analyze a road once and assume the environment will remain unchanged.
A pedestrian can enter the road, another car can brake, and a traffic signal can change within moments.
The system must keep updating its calculations as new information arrives.
10. What Happens When a Self-Driving Car Encounters Bad Weather?
One of the biggest engineering challenges is that roads rarely provide ideal conditions.
A perception system may perform well during a clear afternoon but face additional difficulties during heavy rain, thick fog, snowfall, or nighttime driving.
Each sensor experiences different limitations.
Heavy rain: Water droplets can interfere with camera visibility and affect LiDAR measurements. Radar can provide useful complementary information.
Fog: Reduced visibility makes it harder for optical sensors to detect distant objects. Radar may retain useful detection capabilities, although it is not immune to environmental interference.
Night driving: Cameras need adequate illumination or specialized low-light capabilities. Radar can help monitor moving vehicles independently of visible lighting.
Snow: Snow can cover lane markings, obstruct cameras, and create confusing visual patterns. It may also interfere with LiDAR returns.
Direct sunlight: Strong glare can affect camera images, making it harder to identify traffic signals, road markings, or other objects.
This explains why autonomous driving developers invest heavily in testing under different environmental conditions.
The goal is not to build a vehicle that performs perfectly in one controlled demonstration. It is to develop a system that can recognize when its perception is unreliable and respond safely.
11. Why Self-Driving Cars Still Make Mistakes
Despite improvements in sensors and AI models, autonomous vehicles are not immune to perception errors.
Some road situations are particularly difficult because they are unusual, unpredictable, or poorly represented in training data.
Consider a few examples:
Unusual road objects: A fallen mattress, a damaged traffic cone, or an object carried by strong wind may not resemble familiar training examples.
Partially hidden pedestrians: A person stepping out from behind a parked truck may become visible only when the vehicle has limited time to react.
Unusual road markings: Temporary construction markings can conflict with permanent lane markings, creating ambiguity.
Unexpected human behaviour: A driver may suddenly reverse, a cyclist may ignore a traffic signal, or a pedestrian may cross outside a designated area.
These situations are often described as edge cases.
They matter because autonomous driving systems must handle more than ordinary traffic patterns. A system that performs exceptionally well on familiar roads can still struggle when it encounters something unusual.
Developers address these challenges through extensive simulation, real-world testing, improved training datasets, sensor redundancy, and continuous evaluation.
However, testing cannot guarantee that every possible road situation has been anticipated.
12. Do All Self-Driving Cars Use the Same Technology?
No. Different manufacturers follow different engineering strategies.
Some autonomous driving platforms use a combination of cameras, LiDAR, and radar. Others place greater emphasis on camera-based perception and AI-powered visual processing.
These approaches involve different trade-offs.
| Technology approach | Main advantage | Main consideration |
|---|---|---|
| Camera-based systems | Rich visual information and comparatively lower sensor costs | Dependence on image quality and AI interpretation |
| LiDAR-based systems | Detailed 3D distance measurements | Hardware expense and environmental limitations |
| Radar-supported systems | Useful distance and velocity measurements | Less visual detail than cameras |
| Multi-sensor systems | Multiple sources of complementary information | Greater hardware and integration complexity |
There is no universal sensor configuration that automatically guarantees safe autonomous driving.
The quality of the perception software, sensor calibration, computing hardware, system architecture, and operational testing all matter.
For a deeper technical look at how these components connect, autonomous driving perception tutorials provide additional material on sensor hardware, computer vision, navigation, and perception pipelines.
13. Can a Self-Driving Car See Better Than a Human?
This is an interesting question, but the answer depends on what we mean by seeing better.
A human driver has natural visual perception, experience, contextual judgment, and the ability to interpret unusual situations.
A machine has different advantages.
It can process multiple sensor streams simultaneously, measure distances electronically, track several moving objects, and monitor areas that might be outside a human driver’s direct field of view.
Radar can also measure relative velocity without relying on visible light.
However, machines can struggle with situations that humans interpret almost instinctively.
For example, a human driver may recognize that a cardboard box moving across the road is probably being blown by the wind. An autonomous system must classify the object, estimate its movement, evaluate the surrounding conditions, and decide how to respond.
The difference is not simply about which one has better vision.
It is about how effectively each system converts sensory information into safe decisions.
The most important measure of autonomous perception is therefore not how impressive a demonstration looks, but how consistently the complete system performs across ordinary and unusual driving conditions.
14. What the Future of Autonomous Vehicle Vision May Look Like
The technology is still evolving, and several developments could significantly improve how autonomous vehicles perceive their surroundings.
More advanced AI perception models
Newer neural network architectures may improve object recognition, depth estimation, motion prediction, and the interpretation of complicated road environments.
Higher-resolution radar
Imaging radar could provide more detailed information about surrounding objects while retaining some of radar’s advantages in challenging weather.
Improved LiDAR hardware
Smaller, more affordable, and more efficient LiDAR systems could make detailed three-dimensional sensing easier to integrate into different vehicle categories.
Vehicle-to-everything communication
Connected vehicles may exchange information with other vehicles and compatible road infrastructure. This could provide additional warnings about hazards, traffic conditions, and road closures.
More realistic simulation
Developers can test autonomous driving software in virtual environments containing unusual traffic situations, environmental changes, and potentially dangerous scenarios.
These developments may improve perception capabilities, but they will also require careful validation before being trusted in real-world driving environments.
Final Thoughts: A Self-Driving Car Sees Through Data, Not Human Eyes
The next time you see a self-driving vehicle moving through traffic, remember that its ability to navigate does not come from one camera or a single artificial intelligence model.
It comes from an entire perception architecture.
Cameras provide visual information. LiDAR measures three-dimensional distances. Radar tracks objects and their movement. Ultrasonic sensors assist with nearby obstacles, while GPS and IMU technologies help establish the vehicle’s position.
Artificial intelligence connects these different sources, identifies objects, tracks movement, estimates possible future actions, and provides information for the driving decision system.
The remarkable part is how quickly these processes must work together.
A self-driving vehicle needs to continuously interpret a changing environment while accounting for uncertainty, unexpected behaviour, and sensor limitations.
There is still considerable engineering work involved before autonomous driving can operate reliably across every road, weather condition, and traffic situation.
But one thing is already clear: the future of vehicle perception is not simply about giving cars better cameras. It is about building intelligent systems that can turn enormous amounts of sensory data into accurate, timely, and responsible decisions.
I am the Founder and Content Creator of this website. I write informative and research-driven articles covering technology, artificial intelligence, digital innovation, and emerging trends. My goal is to provide readers with valuable insights and practical knowledge. Connect with me on LinkedIn